Technical Design Report of Matsya 6D, Autonomous Underwater Vehicle
Sep 13, 2024··
0 min read
Co-author
Abstract
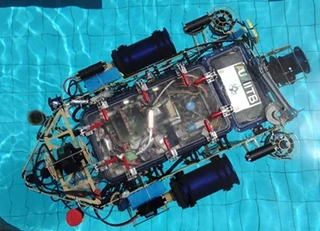
This year, for RoboSub 2024, Team AUV-IITBis bringing into action Mastya 6D, with new actuation systems, a reliable electrical stack and a brand-new codebase. A novel gripper was designed employing soft robotics, considering the versatility of the objects to be picked. The torpedo shooterwas made simpler and easier to reload. The existing SubConn connector was replaced with our in-house connector for ease during testing and improved speeds. The power board was made smaller, and a high degree of redundancy was incorporated to ensure smooth functioning. The cameras were changed to provide a wider field of view, brighter feed, and a high data transfer rate. Most importantly, the entire software architecture was revamped to use Python instead of C++, thus making use of its extensive library support and improving readability. Finally, extensive and rigorous testing was performed on the vehicle, ensuring all functionalities were well-tested and capable.
Type
Publication
Published